Alexander
Bugar.

I like tinkering with hardware as much as I like writing code, especially when I can use both to build systems where complex behavior emerges from simple rules.

Computer Engineering · USF · May 2028 ·Open to internships

My Projects

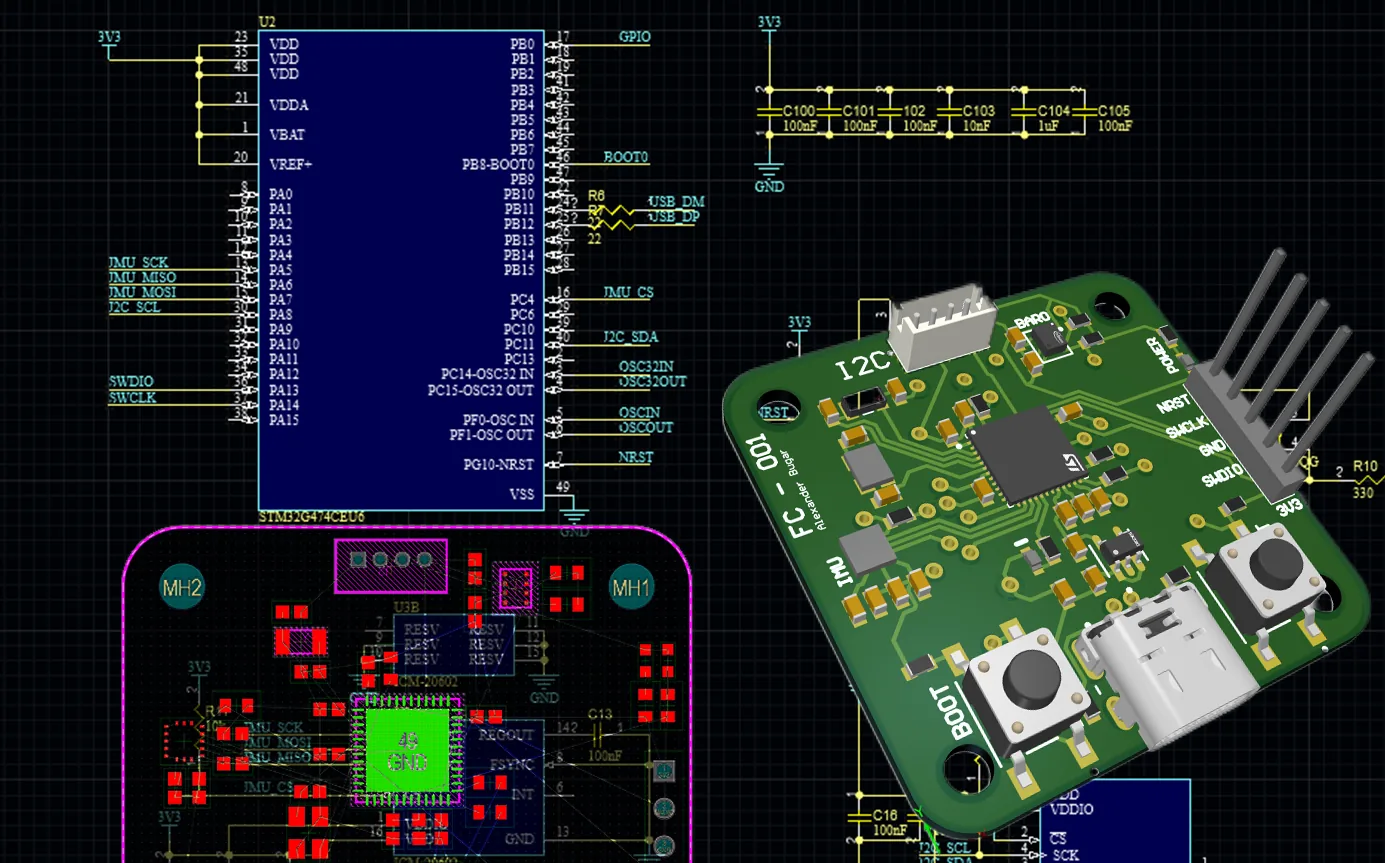
STM32 flight-controller prototype and development hardware

The Flight Control System

STM32 · FreeRTOS · Sensor Fusion · Custom PCB

A flight-control stack built across the firmware and the board it runs on. It pairs deterministic STM32 sensor and control tasks with a custom board for the MCU, IMU, power, logging, and motor outputs.

Build progress

Prototype & driver bring-up Estimation & control Board layout & routing Board bring-up & flight test
N-BODY · CUDA
Active

The N-Body Simulator

C++ · CUDA · Numerical Methods

A gravitational N-body simulator in C++ with a CUDA backend, built to study integrator accuracy and energy conservation under close encounters, and to measure where a naive O(N²) kernel actually spends its time on a consumer GPU.

Build progress

Active

The Drone Simulation & HIL System

C++17 · Vulkan · UDP/UART · Hardware-in-the-loop

A 120 Hz rigid-body simulation and the bridge that connects it to embedded targets. The engine models the drone, sensors, rotors, wind, and controllers while the bridge moves state and actuator commands over CRC-protected UDP and UART packets.

Build progress

Physics core & Vulkan editor Packet protocol & ESP32 bridge Aerodynamics & sensor fidelity Closed-loop bench HIL

The Flight Control System

The firmware and PCB are developed as one system. Choose a module for its implementation details, engineering decisions, and build log.

STM32 flight-controller firmware development hardware

Flight Controller Firmware

FreeRTOS · 1 ms IMU loop · Sensor fusion

STM32 firmware split into driver, estimator, control, and communication layers, with DMA sensor acquisition, USB CDC telemetry, and estimator testing against recorded data.

Render of the custom STM32H7 flight-control board

Flight Control Board

STM32H7 · Altium · Power & motor outputs

A custom target board carrying the MCU, IMU, onboard logging, battery-side regulation, communication buses, and motor outputs needed by the firmware.

The Drone Simulation & HIL System

The engine supplies the simulated world. The bridge carries sensor state and actuator commands between that world and embedded hardware.

Vulkan editor for the drone physics simulation

Simulation Engine

C++17 · Vulkan · 120 Hz rigid-body physics

A headless fixed-step physics core with a native editor, physical rotors, cascaded controllers, wind, sensors, collision handling, and a flyable drone.

Simulation Bridge

UDP · UART · CRC-32 · ESP32

A framed transport layer that streams simulation state to firmware and returns actuator commands, providing the connection needed for closed-loop hardware-in-the-loop testing.

Research

Ongoing

Systems Research

GPU Workload · Profiling · Scheduling

Undergraduate researcher at USF's College of AI, Cybersecurity and Computing, studying how to automatically decide where different components of a multimodal AI model should run by measuring how they actually behave on real hardware, instead of relying on fixed placement rules. The work is systems research: profiling, scheduling, resource allocation, and runtime optimization across heterogeneous GPUs. Still early, currently surveying the literature and defining what needs to be measured. More to come.

The tools

Languages

  • C
  • C++
  • CUDA
  • Python

Systems & Embedded

  • Linux · FreeRTOS
  • STM32 HAL · ESP32
  • SPI · UART · I2C · DMA
  • USB CDC · PWM · GPIO

Tooling

  • Google Test · CMake · Git
  • CUDA profiling · Benchmarking
  • PlatformIO · STM32CubeMX
  • Altium Designer · PCB Layout

Where I study

2026–2028

University of South Florida

B.S. Computer Engineering · Tampa, Florida

In progress
Expected May 2028

Who I am

I'm a twenty-one-year-old computer engineer from Vorarlberg, Austria, based in Tampa Bay, Florida.

I like following a system from the moment a sensor produces data to the point where code turns it into a decision. What interests me most is the behavior that emerges when simple rules, feedback loops, and physical hardware begin interacting.

BasedTampa, Florida
FocusSimulation · GPU · Parallel Computing
LanguagesEN · DE · RO
OriginVorarlberg, Austria
Status(CPT) Open to Internships